H2 Plus
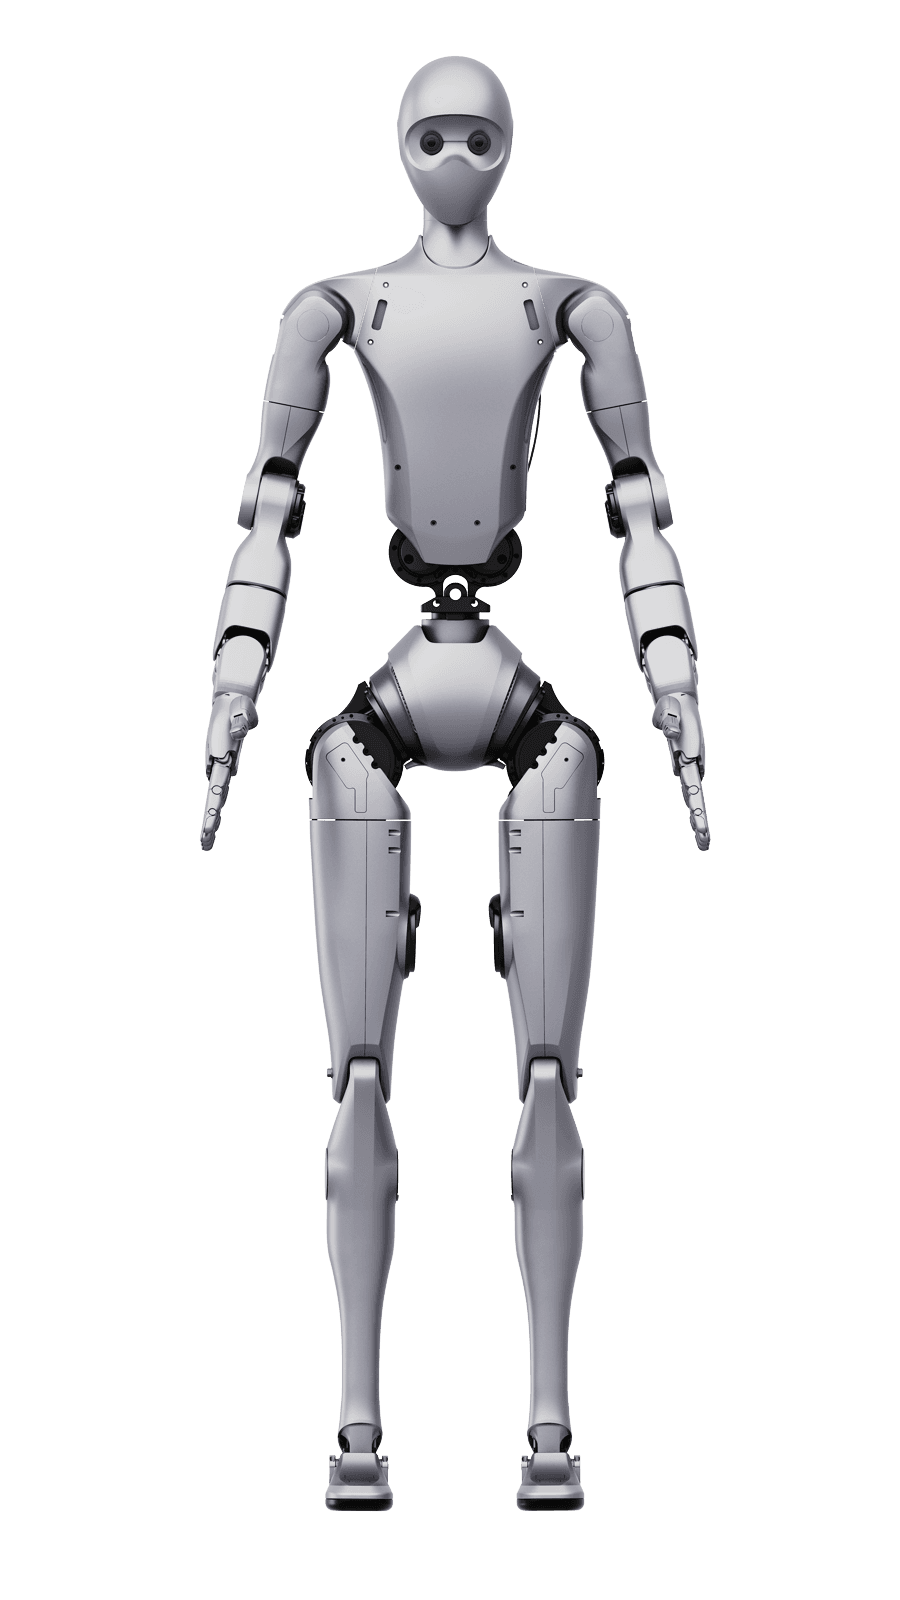
The same body as the H2, but with hands and a computer a class stronger. Each hand has twenty-two moving joints and more than a thousand tactile points per fingertip. This is the version for those who will also develop on the robot.
- Degrees of freedom (number of joint motors)
- 31
- Degrees of freedom per leg
- 6
- Degrees of freedom per arm
- 7
- Waist degrees of freedom
- 3
- 22moving joints per hand
- 150 Nof grip force
- 128 GBof memory for inference on the device itself
- ±1 mmfingertip position repeatability
Hands, not grippers
Twenty-two moving joints per hand, a grip force of a hundred and fifty newtons and repeatability to the millimetre. The difference between grabbing and handling an object sits right there.
It feels what it holds
More than a thousand tactile points per fingertip and force sensing from nearly zero. A robot that cannot feel force cannot pick up an egg; this one can.
A computer for on-robot development
A strong inference module directly on the device, a hundred and twenty-eight gigabytes of memory and open development. The model runs on the robot and not in the cloud, which for privacy and for latency is the same question.
For research and for showing what is possible
This is not the robot that walks a visitor to a shelf. This is a device you work on: a lab, a university, a development team that wants hands and touch, not only walking.
| Height × width × depth (standing) | 1820 x 456 x 218mm |
|---|---|
| Weight (with battery) | About 70kg |
| Degrees of freedom (number of joint motors) | 31 |
| Degrees of freedom per leg | 6 |
| Degrees of freedom per arm | 7 |
| Waist degrees of freedom | 3 |
| Head degrees of freedom | 2 |
| Joint output bearings | Industrial-grade crossed roller bearings (high precision, high load capacity) |
| Joint motors | Low-inertia high-speed inner-rotor permanent magnet synchronous motors (better response speed and heat dissipation) |
| Maximum arm joint peak torque | 120N.m |
| Maximum leg joint peak torque | 360N.m |
| Maximum arm payload | Peak: approx. 15kg; Rated: approx. 7kg |
| Lower and upper leg length | 1045mm |
| Forearm and upper arm length | 690mm |
| Body material | Aerospace-grade aluminum + titanium alloy + high-strength engineering plastics |
| Cooling system | Air Cooling |
| Power supply method | Low-Resistance High-Quality Lithium Battery |
| Battery voltage | Maximum Voltage: 75.6V |
| Base computing power | PC1: Intel Core i5 (Platform Functions) PC2: Intel Core i7 (User Development) |
| Perception sensors | Wide-FOV Humanoid Binocular Camera |
| External interfaces | USB3.0 x 3 USB+DP x 3 GMSL x 4 Gigabit Ethernet x 4 USB2.0 x 2 RS485 x 4 CAN x 2 Power Outputs:12V x 1;24V x 2;BAT x 1 |
| Voice interaction | Voice interaction via array microphones and high-power speakers |
| Wi-Fi 6, Bluetooth 5.2 | Yes |
| High-performance computing module | NV JetsonTM T5000 |
| Smart battery (quick release) | Yes |
| Charger | Yes |
| Handheld remote controller | Yes |
| AI performance | 2070 TFLOPS (FP4—sparse) |
| GPU | 2560-core NV Blackwell Architecture GPU with 5th-Generation Tensor Cores Multi-Instance GPU with 10 TPCs |
| GPU maximum frequency | 1.57 GHz |
| CPU | 14-core Arm ® Neoverse ® -V3AE 64-bit CPU 1 MB L2 cache per core 16 MB shared system L3 cache |
| CPU maximum frequency | 2.6 GHz |
| Vision accelerator | 1x PVA v3 |
| Memory | 128 GB 256-bit LPDDR5X 273 GB/s |
| Storage | Supports NVMe through PCle Supports SSD through USB3.2 |
| Video encoding | 2x NVENC |
| Video decoding | 2x NVDEC |
| Binocular head camera | Horizontal FOV 140°±3; Vertical FOV 102°±3; Aperture 2.0; Focal Length 2.67mm; Depth of Field 0.4m-INF; global shutter; |
| Wrist cameras (optional) | 3MP ultra-wide-angle, HFOV 196°, VFOV 154°,Global shutter |
| Dexterous hand weight | 1.3KG |
| Dexterous hand dimensions | 208 x 90 x 50mm |
| Active degrees of freedom per hand | 22 |
| Dexterous hand payload | 30Kg |
| Hand grip force | 150N |
| Fingertip force | 20N |
| Hand operating speed | >4Hz |
| Fingertip positional repeatability | ±1mm |
| Number of tactile points on the hand | >1000 tactile pixels per fingertip |
| Force detection range | Range 0–30N, Sensitivity 0.005N |
| Smart OTA upgrade | Yes |
| Secondary development | Yes |
Works the whole opening time. When it gets quieter, it returns to the charging station by itself, and is back before you need it again. The robot complements your staff, it never replaces them.
Events and fairs
A stand people notice, and a conversation instead of a pile of leaflets.
Museums and tourism
Greeting and guiding in several languages, in the same spot every day.
Research and education
A lab that needs an open platform, not a closed toy.
- When the H2 Plus and when the plain H2?
- The H2 is for settings where the robot speaks, guides and makes an impression. The H2 Plus is for those who will grip, touch and develop with it. If in your use the robot picks up nothing, the H2 Plus is more machine than you need.
- Can we develop on it ourselves?
- Yes. The device is open for development and has external ports for sensors and accessories. We handle supply, setup and support; the code can be yours.
- What is the lead time?
- It depends on the configuration and on what the manufacturer has in stock. We give it within two working days together with the quote, because guessing here costs more than waiting for the answer.
Pick by the measurement, not by the brochure.
| Model | Forearm and upper arm length | Cooling system | Charger | Power supply |
|---|---|---|---|---|
| G1 | — | — | — | — |
| H1 | — | — | — | — |
| H2 | 690mm | Local air cooling | YES | Premium Lithium Battery with Low Internal Resistance |
| H2 PlusTHIS PAGE | 690mm | Air Cooling | YES | — |
| AgiBot G2 | — | — | — | — |
| R1 | 420 | Local air cooling | YES | Lithium battery |
| R1-A5 | 420mm | Local Air Cooling | Included | External Power or Li-ion Battery |
| R1-A5-D | 420mm | Local Air Cooling | Included | External Power or Li-ion Battery |
| R1-A7 | 555mm | Local Air Cooling | Included | External Power or Li-ion Battery |
| R1-A7-D | 555mm | Local Air Cooling | Included | External Power or Li-ion Battery |
Enquiry
Tell us where the robot should stand.
Within two working days you get a proposal for your space and a date to see the robot working. No phone call, no obligation.
Or directlyinfo@vandri-robotics.com